This concluding segment of a pivotal series delves into how an acute focus on system integration is indispensable for achieving genuine precision in complex motion control applications. Authored by Corey Foster, Director of Automation Sales & Application Engineering at Valin Corporation, this insights-driven examination underscores the often-underestimated role of holistic system design beyond individual component specifications.
The Evolving Landscape of Precision Motion Control
In the realm of high-precision motion control, a common pitfall is the myopic evaluation of system performance based solely on the isolated specifications of mechanical components. Actuators, for instance, are frequently selected based on standard metrics such as repeatability, accuracy, and load capability. While this approach suffices for many routine applications, the escalating demands for ultra-precision across industries—from semiconductor manufacturing to advanced medical diagnostics and additive manufacturing—necessitate a much deeper, systemic understanding. Achieving truly groundbreaking precision requires an integrated perspective that encompasses the entire motion control ecosystem, including mechanics, motors, drives, and sophisticated control systems.
This series has systematically peeled back the layers of technology contributing to overall system performance. The inaugural article explored the foundational mechanics, highlighting often-overlooked yet critical factors like bearing deflection, body stiffness, and structural smoothness. The second installment shifted focus to the motors, scrutinizing their diverse designs, construction methodologies, quality benchmarks, and performance determinants. The third part meticulously discussed the paramount importance of the designs and features inherent in drives and controls. Now, in this fourth and final article, the spotlight turns to the most critical, yet frequently underestimated, element: system integration itself.
A recurring theme woven throughout this comprehensive series is the existence of crucial details that, despite their profound impact, remain conspicuously absent from standard data sheets. These ‘hidden’ variables can either enable or irrevocably undermine the high-performance expectations of an entire system. As motion systems push the boundaries beyond micron-level accuracy—venturing into nanometer ranges in some advanced applications—traditional specifications begin to lose their typical meaning and direct relevance. This paradigm shift mandates nuanced engineering decisions, where every choice, no matter how seemingly minor, carries significant weight. The overarching aim of this series is to equip engineers, designers, and system integrators with the insights necessary to recognize and address the intricate interplay of components in constructing a high-precision motion system.
Understanding Performance Tiers: A Framework for Integration
Previous articles in this series introduced a tiered framework for evaluating motion control system performance: basic, specification-level, and pushing-beyond-the-specifications performance. This framework is equally pertinent when considering the integration of components. Basic performance might be achieved when components are simply assembled and function. Specification-level performance occurs when individual components meet their stated data sheet metrics. However, true high-precision, or ‘pushing-beyond-the-specifications’ performance, is only attainable when the entire system is meticulously integrated, optimizing the synergistic interaction of all its constituent parts.
System Integration: Precision by Design, Not by Chance
The notion that disparate components can be "thrown together" and somehow function optimally, at least initially, is a dangerous misconception in high-precision engineering. While an initial concept might validate basic functionality, the long-term sustainability and performance consistency of such an assembly are often compromised. As operational demands intensify, or as subsequent generations of a product require enhanced performance, latent problems invariably surface. The analogy of a paper airplane serves as an apt illustration: a simply folded paper plane might fly, but repeated flights and crashes degrade its performance. To achieve greater distance and accuracy, the folds must become more precise, crisper, and cleaner, even with the same fundamental design.
This principle translates directly to motion control systems. Even a meticulously designed motion control sub-system—comprising advanced mechanics, motors, and drives—will invariably fall short of its potential if the overarching system is not thoughtfully engineered and rigorously integrated. Optimal performance is not an inherent attribute of individual sub-systems but rather an emergent property of the meticulously integrated whole. Industry data frequently indicates that a significant percentage of system failures in complex automation projects are attributable to integration issues rather than individual component malfunctions. A 2022 survey by the Association for Advancing Automation (A3) highlighted that while component reliability is high, system downtime often stems from unforeseen interactions and environmental factors not accounted for during initial component selection.
Real-World Integration Failures: The Cost of Overlooking Details

System integration is fundamentally the art and science of enabling all mechanical, motor, drive, and control components to operate at their full potential, harmoniously interacting with the surrounding system infrastructure. Every published specification for these components is predicated upon a set of often-unarticulated, hidden assumptions that the operational environment and mounting conditions must satisfy for the components to achieve their stated performance. For instance, mechanical actuators implicitly assume certain levels of flatness, rigidity, and stability from their mounting surfaces. Motors presuppose adequate airflow and heat sinking capabilities to dissipate thermal energy effectively. Drives and controllers, similarly, operate under the assumption of a clean, stable, and appropriately grounded electrical power supply.
Consider the precision linear motor, a cornerstone in many advanced applications. Its performance is profoundly affected by the flatness and rigidity of its mounting surface and its precise alignment with the linear bearings that support the load. When a linear motor is paired with linear guides on both sides, a complex three-component system emerges. Any deviation from precise alignment in this configuration can induce mechanical binding. At best, this leads to increased, uneven friction and accelerated wear, degrading accuracy and reducing lifespan. At worst, it can cause complete binding, preventing the motor from moving altogether. The financial implications of such a failure extend beyond mere replacement costs; they encompass production downtime, quality control issues, and potential damage to other system components. For instance, in semiconductor lithography, even micron-level misalignment can result in defective wafers, costing millions of dollars in scrapped material and lost production time.
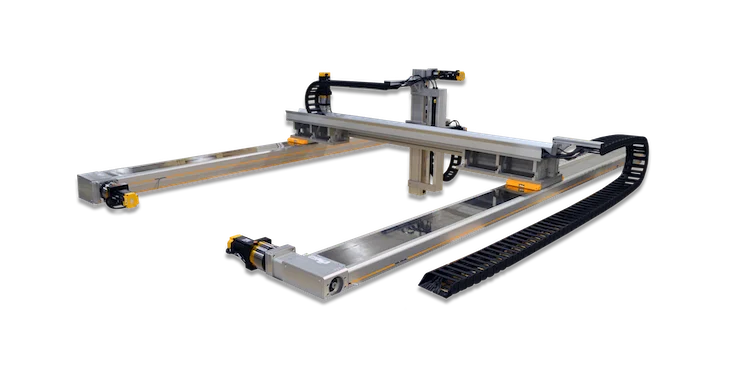
Another common challenge arises with two long linear belt and pulley actuators operating in parallel within a system. Beyond the alignment challenges akin to linear motors, these systems introduce an additional layer of complexity: the need for precisely matched travel lengths. Variations in belt tension between the two actuators directly translate to differing distances per revolution of their respective pulleys. While seemingly minor over short travel distances, this discrepancy can become highly significant over extended ranges. For example, over a two-meter travel length, a mere 5-millimeter variance between the two actuators at the end of travel can be catastrophic in applications demanding sub-millimeter precision. Such deviations can lead to uneven loading, premature wear, and unacceptable positional errors in synchronized operations.
The electrical environment also poses significant integration challenges. Controllers and drives are typically developed and tested in controlled laboratory or workshop environments, where electrical power is pristine and stable. Consequently, critical considerations such as robust grounding techniques, comprehensive shielding, and effective Electromagnetic Compatibility (EMC) filters may be overlooked or deemed unnecessary during initial prototyping. However, once that same system is deployed into an industrial field environment—often characterized by "dirty" power sources, transient voltage spikes, and electromagnetic noise from heavy machinery—these shortcuts can severely compromise system performance. Unstable power can lead to intermittent operation, communication errors, sensor noise, and even component damage, resulting in unpredictable behavior and costly downtime. A 2021 study by the Electrical Apparatus Service Association (EASA) estimated that power quality issues account for approximately 15-20% of all industrial equipment failures.
Furthermore, thermal management is an often-underestimated aspect of integration. A system assembled in a climate-controlled workshop may be destined for deployment in a hot industrial environment or one with significant temperature fluctuations. Thermal expansion, a fundamental physical phenomenon, can directly impact all mechanical alignments, clearances, and the performance characteristics of motors and bearings. Even a few degrees Celsius change can cause components to expand or contract differentially, leading to binding, increased friction, or loss of precision. For example, in a large gantry system made of steel, a 10°C temperature rise can result in several hundred microns of linear expansion over a two-meter length, completely undermining micron-level accuracy requirements.
Integration Practices That Matter: Building for Robust Precision
To mitigate these risks and consistently achieve high-precision outcomes, several best practices in system integration must be rigorously implemented:
- Mounting Surface Integrity and Precision Alignment: The surfaces upon which actuators are mounted must not merely meet but often exceed the assumed standards of the actuators and the specific application. Precision machining of mounting surfaces to ensure extreme flatness and perpendicularity is paramount. The use of dowel pins, particularly between actuators and their mounting surfaces (or between stacked actuators), is crucial for ensuring repeatable assembly. Dowel pins provide positive location and maintain alignment even after disassembly for maintenance or re-assembly, preventing cumulative positional errors.
- Encoder Alignment and Calibration: For axes incorporating precision encoders—whether linear, rotary, or ring-type—meticulous alignment is non-negotiable. Many high-resolution encoders demand specific installation tolerances, often in the order of a few arc-seconds or microns. This frequently necessitates specialized fixtures, precision measurement tools (e.g., laser interferometers, autocollimators), and iterative calibration procedures to ensure optimal signal quality and accuracy. Improper encoder alignment can introduce cyclical errors, offset errors, and reduce overall system resolution.
- Strategic Cable Routing and Management: Cable routing is a discipline often relegated to an afterthought, yet its impact on signal integrity and system performance is profound. A fundamental principle is to segregate lower-power, sensitive signal cables from high-power cables. They should run in separate conduits or trays and, if they must cross, should do so perpendicularly to minimize electromagnetic interference (EMI). Running them in parallel over long distances in the same tray creates an antenna effect, inducing noise into sensitive control signals. Additionally, coiling excess high-power cable should be strictly avoided, as it creates inductive loops that can generate significant EMI. Proper shielding, grounding, and the use of twisted-pair cabling for differential signals are also critical.
- Environmental Isolation and Control: Ultra-high precision systems are exquisitely sensitive to their surrounding environment. Isolating them from detrimental external influences is often paramount.
- Vibration Dampers: Passive or active vibration isolation systems are essential to decouple the precision motion system from ground-borne vibrations caused by nearby machinery, foot traffic, or even distant seismic activity. Active vibration cancellation systems, utilizing accelerometers and actuators, can provide isolation down to sub-Hertz frequencies.
- Temperature Control: Maintaining a stable, temperature-controlled environment is crucial. Precision systems are often housed in dedicated rooms with tight temperature regulation (e.g., ±0.1°C or better). This minimizes thermal expansion/contraction effects that can compromise mechanical alignment and sensor accuracy.
- Humidity and Cleanliness: In many applications (e.g., semiconductor manufacturing), controlling humidity and particulate contamination is equally vital. Cleanroom environments, rated according to ISO standards, prevent dust and other contaminants from interfering with delicate mechanisms or optical systems.
- Foundation Isolation: The highest precision systems, such as those used in metrology or advanced research, are frequently installed on separate, isolated foundations that are physically decoupled from the rest of the facility’s structure. This prevents building vibrations from transmitting to the precision equipment.
Guiding Questions for the Systems Engineer
The successful integration of high-precision motion control systems hinges on a proactive, inquisitive approach. Engineers must transcend the role of a mere "product selector" and embrace the mindset of a comprehensive "systems engineer." This involves posing critical questions throughout the design, assembly, and commissioning phases:
- Mechanical Interface: Does the mounting surface meet or exceed the actuator’s flatness, stiffness, and parallelism requirements? How will thermal expansion of the mounting surface affect the system over its operational temperature range? Are all mechanical interfaces properly doweled and torqued to prevent creep or misalignment over time?
- Dynamic Loading: Have all dynamic loads, including acceleration, deceleration, and external forces, been accurately accounted for in the mechanical design and component selection? How do these loads affect bearing life, motor sizing, and structural deflection?
- Electrical Power Quality: Is the incoming power supply truly clean and stable, or are there potential sources of noise, surges, or sags in the industrial environment? What grounding scheme is being implemented, and is it robust enough to prevent ground loops and ensure EMC? Are appropriate line filters, surge protectors, and shielded cables specified?
- Thermal Management: What is the anticipated operational temperature range, and how will temperature fluctuations affect the performance of motors, bearings, sensors, and structural components? Is the cooling system (active or passive) sufficient for all components under worst-case loading and ambient conditions?
- Vibration Environment: What are the expected vibration levels at the installation site, and how will they impact the system’s precision? Is passive or active vibration isolation necessary, and how will it be implemented and tested?
- Sensor and Feedback Integrity: How will the chosen feedback devices (encoders, resolvers, force sensors) be protected from environmental interference, mechanical shock, and electrical noise? Is the resolution and accuracy of the feedback system sufficient for the desired overall system precision?
- Cable Management: Are signal cables separated from power cables? Are they adequately shielded and grounded? Is there sufficient strain relief to prevent damage over millions of cycles?
- Software and Control Algorithms: Is the control algorithm robust enough to handle dynamic changes, disturbances, and component variations? Have all tuning parameters been optimized for the entire integrated system, not just individual axes?
- Maintenance and Repeatability: Can the system be easily disassembled, maintained, and re-assembled without losing critical alignment or requiring extensive recalibration? What tools and procedures are necessary to ensure consistent performance after maintenance?
- Long-Term Drift: What factors might lead to performance degradation or drift over extended operational periods (e.g., wear, material fatigue, environmental changes), and how can these be mitigated or compensated for?
In conclusion, the unasked questions and overlooked details are invariably the ones that will ultimately compromise a high-performance motion control system. For any application demanding elevated levels of precision, speed, or reliability, a holistic, systems-engineering approach is not merely beneficial; it is absolutely imperative. Engineers must move beyond simply selecting components based on data sheets and instead cultivate a deep understanding of how these components interact within a complex, dynamic environment. The future of advanced manufacturing and scientific discovery hinges on this integrated perspective, transforming individual specifications into collective, unparalleled precision.
This article is the final installment in a series dedicated to understanding the intricate layers of performance and specifications in motion control. Readers are encouraged to revisit the previous articles for a comprehensive understanding:
Part 1: Layers of performance and specifications in motion control
Part 2: Layers of performance and specifications in motion control
Part 3: Layers of performance and specifications in motion control