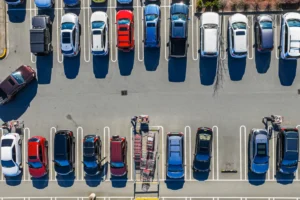
It’s a frustratingly common scenario: a driver, relying on a navigation app to estimate their travel time, arrives at their destination only to find a complete lack of parking. The subsequent hunt for a spot can add significant, unpredictable delays to their journey, turning a swift trip across town into a time-consuming ordeal. This widespread issue, more than just an inconvenience, contributes to urban congestion, inflates vehicle emissions, and can even deter individuals from opting for public transportation due to the perceived inefficiency of driving and parking. Addressing this critical gap in current navigation technology, a team of researchers at the Massachusetts Institute of Technology (MIT) has developed an innovative system designed to factor in parking availability, promising more accurate travel time estimations and a more efficient urban mobility experience.
The prevailing navigation systems, while adept at calculating driving routes and estimating transit times, largely overlook the crucial element of parking. This oversight leads to a significant underestimation of total trip duration, impacting not only individual schedules but also the broader urban environment. The hours drivers spend circling blocks in search of parking contribute directly to traffic jams and increased air pollution. Furthermore, this unreliability can create a distorted perception of travel efficiency, making public transit seem less appealing than it might actually be, especially when factoring in the hidden costs of parking.
The MIT researchers, hailing from the Laboratory for Information and Decision Systems (LIDS) and the Department of Civil and Environmental Engineering (CEE), have engineered a sophisticated, probability-aware approach. Their system aims to guide drivers not directly to their final destination, but to the parking lot that offers the optimal balance between proximity to the desired location and a high probability of securing a parking spot. This paradigm shift in navigation strategy has demonstrated remarkable potential in simulated real-world conditions.
Groundbreaking Simulation Results
In extensive simulated tests utilizing real-world traffic data from Seattle, a notoriously congested urban center, the MIT system achieved an impressive reduction in travel time, particularly in the most challenging traffic scenarios. The simulations indicated potential time savings of up to 66 percent in highly congested settings. For an individual motorist, this translates to an average reduction of approximately 35 minutes per trip, a substantial improvement compared to the current practice of arriving at a destination and then facing the uncertainty of finding parking. This significant saving underscores the tangible benefits of a navigation system that accounts for the often-overlooked "last mile" of a journey.
While a fully deployable, real-world version of the system is still under development, the researchers’ demonstrations have robustly validated the viability and efficacy of their approach. The findings suggest a clear pathway for implementation in future navigation technologies.
Addressing the "Parking Frustration" Systematically
Cameron Hickert, an MIT graduate student and lead author of the paper detailing this research, articulated the core motivation behind their work: "This frustration is real and felt by a lot of people, and the bigger issue here is that systematically underestimating these drive times prevents people from making informed choices. It makes it that much harder for people to make shifts to public transit, bikes, or alternative forms of transportation." His sentiment highlights the broader societal implications of accurate travel time estimations, particularly in encouraging sustainable transportation options.
The research paper, published in the prestigious Transactions on Intelligent Transportation Systems, is co-authored by Sirui Li, a PhD candidate; Zhengbing He, a research scientist at LIDS; and senior author Cathy Wu, an Associate Professor in CEE and the Institute for Data, Systems, and Society (IDSS) at MIT, and a member of LIDS. The collaborative effort signifies a significant step forward in the field of intelligent transportation systems.
A Probabilistic Approach to Parking
The innovative methodology developed by the MIT team is rooted in a probability-aware framework. It meticulously considers a multitude of factors that influence the success of finding parking. These include:
- All Potential Parking Lots: The system analyzes all public parking facilities in proximity to the user’s ultimate destination.
- Driving Distance: It calculates the distance from the user’s current location to each potential parking lot.
- Walking Distance: The time and distance required to walk from each parking lot to the desired destination are also factored in.
- Likelihood of Parking Success: This is the most critical and novel element, incorporating a probabilistic model to estimate the chances of finding an available spot at each location.
At the heart of their approach lies dynamic programming, a mathematical technique that works backward from desired outcomes to determine the optimal sequence of actions. This allows the system to calculate the most efficient route, not just in terms of driving time, but in terms of the total time from origin to destination, including parking and walking.
A key aspect of their model is its ability to handle scenarios where a driver arrives at their intended parking lot only to find it full. The system accounts for the distance to alternative parking facilities and their respective probabilities of success. "If there are several lots nearby that have slightly lower probabilities of success, but are very close to each other, it might be a smarter play to drive there rather than going to the higher-probability lot and hoping to find an opening," Hickert explained. "Our framework can account for that." This nuanced consideration of multiple parking options significantly enhances the system’s robustness and practicality.
The ultimate goal of their system is to identify the optimal parking lot that minimizes the expected total time required for driving, parking, and walking to the destination. This holistic approach moves beyond simply finding the closest available spot.
Accounting for the Actions of Other Drivers
Recognizing that urban parking is a dynamic and competitive environment, the MIT researchers have incorporated the influence of other drivers into their model. The probability of finding a parking spot is not an isolated variable; it is directly affected by the actions of other motorists. The system accounts for several complex interactions:
- First Come, First Served: Another driver might arrive at the user’s preferred parking lot before them and occupy the last available space.
- Sequential Lot Selection: A motorist might attempt to park in one lot, fail to find a spot, and then proceed to another, potentially impacting the availability at the user’s target lot.
- Spillover Effects: Parking congestion in one lot can lead to drivers seeking spaces in adjacent lots, thereby reducing the probability of success for others.
"With our framework, we show how you can model all those scenarios in a very clean and principled manner," Hickert stated. This sophisticated modeling of driver behavior is what elevates their system beyond simple availability predictions.
Leveraging Crowdsourced Data for Real-Time Insights
The accuracy of any parking prediction system hinges on the quality and timeliness of the data it receives. While some parking facilities are equipped with advanced sensors and gates that track occupancy, such infrastructure is not universally implemented. To ensure broader applicability and feasibility for real-world deployment, the MIT researchers explored the effectiveness of using crowdsourced data.
This approach leverages information provided by users and other data streams to infer parking availability. Potential sources of crowdsourced data include:
- User Reporting: Drivers could actively indicate available parking spots or report when they are unable to find parking through a dedicated app.
- Vehicle Circling Data: Tracking the number of vehicles observed circling in search of parking can be an indicator of low availability.
- Unsuccessful Lot Entries: Monitoring the number of vehicles that enter a parking lot and then exit without finding a space can signal congestion.
- Autonomous Vehicle Reporting: In the future, autonomous vehicles, with their inherent sensing capabilities, could automatically report on open parking spots as they navigate urban areas.
"Right now, a lot of that information goes nowhere. But if we could capture it, even by having someone simply tap ‘no parking’ in an app, that could be an important source of information that allows people to make more informed decisions," Hickert emphasized. This highlights the potential for collective intelligence to solve complex urban challenges.
Rigorous Evaluation and Future Directions
The researchers subjected their system to rigorous evaluation using real-world traffic data from the Seattle area. They simulated various scenarios, including congested urban settings and less dense suburban areas, at different times of the day. The results consistently demonstrated the system’s effectiveness. In congested urban environments, the approach not only reduced total travel time by approximately 60 percent compared to simply waiting for a spot to open but also outperformed a strategy of continually driving to the next closest parking lot by about 20 percent.
Furthermore, their analysis indicated that crowdsourced observations of parking availability could achieve an error rate of only about 7 percent when compared to actual parking availability. This finding strongly supports the feasibility and effectiveness of crowdsourcing as a primary method for gathering parking probability data.
Looking ahead, the MIT research team plans to expand their studies. Future work will involve conducting larger-scale investigations utilizing real-time route information across entire cities. They also aim to explore additional innovative avenues for data collection on parking availability, such as analyzing satellite imagery, and to quantify the potential reductions in emissions that could be achieved by their system.
Professor Cathy Wu, a senior author on the paper, underscored the significance of their work in the context of complex urban systems: "Transportation systems are so large and complex that they are really hard to change. What we look for, and what we found with this approach, is small changes that can have a big impact to help people make better choices, reduce congestion, and reduce emissions." This perspective emphasizes the power of targeted technological advancements to drive substantial positive change in urban environments.
The research was generously supported by Cintra, the MIT Energy Initiative, and the National Science Foundation, underscoring the broad recognition of the importance of this innovative approach to urban mobility. This work represents a significant stride towards creating more intelligent, efficient, and user-friendly transportation systems for the future. The implications extend beyond mere convenience, promising a tangible impact on urban livability, environmental sustainability, and the overall efficiency of city life. The integration of parking data into navigation systems is not just an upgrade; it’s a fundamental re-imagining of how we navigate our increasingly complex urban landscapes.