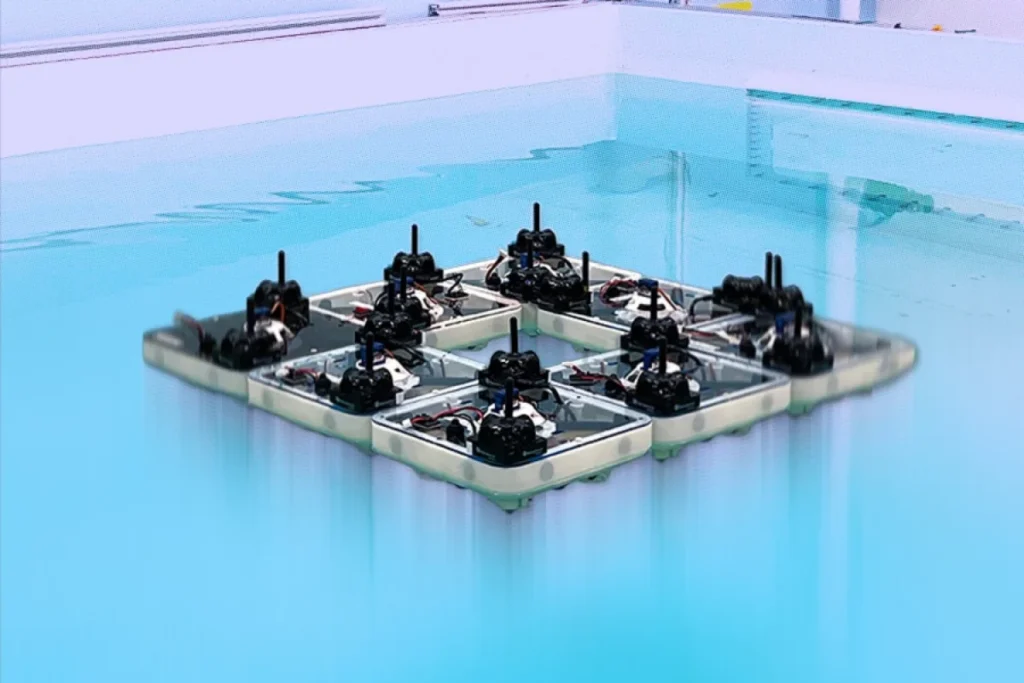
A team of researchers at the Massachusetts Institute of Technology (MIT) has unveiled a groundbreaking robotic system named FloatForm, which reimagines waterfronts as dynamic, adaptable spaces capable of hosting modular, self-assembling infrastructure. This innovative technology utilizes a swarm of small, square robotic boats that can autonomously configure themselves into larger structures, then disassemble and reconfigure into entirely new forms with minimal human oversight. The development promises to unlock new possibilities for urban planning, emergency response, and public space utilization on water.
The FloatForm system comprises individual robotic units, each approximately 21 centimeters square – about the size of a dinner plate. These units are self-contained vessels equipped with integrated thrusters for maneuverability, sensors for environmental awareness, and magnetic latches for interlocking with other robots. The collective capability of these robots points towards a future where floating infrastructure can be fluid and responsive to immediate needs. Imagine temporary platforms erected in the wake of natural disasters to facilitate rescue and relief efforts, bustling floating markets that materialize on urban canals for a designated period, or even stages that emerge for festivals and then seamlessly dissolve once the celebrations conclude.
"Our FloatForm project envisions a future where the waterfront becomes a programmable extension of the city, where autonomous boats can self-organize into bridges, platforms, and other useful structures on demand," stated Daniela Rus, the Panasonic Professor of Electrical Engineering and Computer Science at MIT and director of MIT’s Computer Science and Artificial Intelligence Laboratory (CSAIL). "This kind of distributed robotics opens new possibilities for mobility, emergency response, public space, and infrastructure on water."
Wei Wang, lead author of a new paper detailing the project published in Nature Communications and a former MIT research scientist now heading the Marine Robotics Lab at the University of Wisconsin at Madison, elaborated on the transformative potential. "With FloatForm, we are essentially turning static water surfaces into dynamic, programmable spaces," Wang explained. "Imagine an urban environment where public space isn’t fixed, but can autonomously expand, contract, or reconfigure on demand."
This vision aligns with a broader trend in urban development that seeks to leverage underutilized spaces. Alejandro Gonzalez-Garcia, a former researcher with MIT CSAIL and the Senseable City Lab, who also contributed to the project, highlighted the practical applications. "We see it as forming infrastructure on the water, using a modular system to create one larger system," Gonzalez-Garcia said. "If there’s an emergency, you could form a new bridge to alleviate traffic in the city. Or you could create floating markets and floating stages. If you want a more livable city, you want to use the water, too."
The research, published in an open-access format in Nature Communications, emerges from the collaborative efforts of laboratories led by Professor Rus and Carlo Ratti, professor of practice of urban technologies and planning at MIT and director of the Senseable City Lab. This work builds upon the foundation laid by their earlier project, Roboat, a joint venture with the Amsterdam Institute for Advanced Metropolitan Solutions. Roboat explored the deployment of full-size autonomous vessels in Amsterdam’s canals, canals that historically served as vital arteries for commerce and now primarily accommodate tourism.
Niklas Hagemann, an MIT graduate student in architecture, CSAIL affiliate, and former Senseable City Lab researcher who has been involved since the project’s inception, discussed the evolution of the concept. "We explored whether the canals could be used for waste collection, or for transport, to offload some of the stress on the roads back onto the water," Hagemann remarked. "Urban areas are getting denser, so could you expand public space onto water that’s currently underutilized?"
FloatForm represents a significant scaling down of that initial ambition, focusing on the complex challenge of coordinating dozens, and potentially thousands, of smaller floating robots to achieve collective goals.
Biomimicry Inspires Decentralized Coordination
The breakthrough in enabling such a large number of robots to organize themselves without constant human intervention was inspired by a phenomenon observed in nature: the fire ant raft. Fire ants are renowned for their ability to survive floods by linking their bodies together to form living rafts, a remarkable feat achieved without a designated leader orchestrating the process. Each ant operates based on simple, localized rules, leading to the emergence of a robust and resilient collective structure.
"Each ant is an independent agent," explained Gonzalez-Garcia. "We wanted each robot to have its own capabilities, the same way ant colonies form a raft."
This biological parallel stands in stark contrast to most existing self-assembling robot systems, both terrestrial and aquatic. These systems typically rely on a central computer to dictate every action, a model that is susceptible to single points of failure and proves inefficient as the number of robots increases. The computational demands for planning grow exponentially with scale, and the assembly process often becomes sequential, with many robots idle while awaiting instructions.
FloatForm adopts a fundamentally different approach, shifting the balance of control. A lightweight central planner intervenes only sparingly, primarily to assign each robot its ultimate position within a desired structure, ensuring geometric precision that purely distributed methods often struggle to guarantee. The crucial tasks of navigating toward the target formation, avoiding collisions, and adapting to environmental disturbances are managed onboard each robot. Coordination is achieved through the exchange of positional data with immediate neighbors, allowing the entire swarm to move simultaneously.
This parallel processing capability is a key differentiator. The computational complexity of the FloatForm approach is dependent only on a robot’s immediate surroundings, rather than the total size of the swarm. "What we’re trying to do is to have minimal central intervention, and have them all move together at the same time," Gonzalez-Garcia emphasized.
From Tank Experiments to Collective Transport
In experimental settings at MIT, a fleet of eight FloatForm robots demonstrated remarkable agility. Over multiple trials, they consistently moved from random initial positions to form a target shape, securely latched together into a rigid structure, then disassembled and reassembled into a new configuration. Each complete cycle, from assembly to disassembly and reassembly, took between four and eight minutes.
A particularly compelling demonstration involved collective transport, where the assembled structure moved across a test pool as a single, cohesive vessel. In this mode, a central planner maps out the trajectory for the entire structure, and each individual robot calculates its specific contribution to execute the overall movement. "Every robot becomes an actuator," Gonzalez-Garcia elaborated. Simulations further indicated that this framework scales effectively, with smooth performance observed for swarms comprising up to 64 robots.
"The beauty of this largely decentralized approach is that the computation doesn’t get bogged down as the swarm grows," noted Wang. "Whether you are working with eight boats or 80, the entire fleet coordinates and moves simultaneously. Because the overall assembly time doesn’t significantly increase in principle, the system remains highly scalable."
Beyond the computational advantages, there is a tangible physical benefit to the robots joining together. "Our boats become more stable by joining together, like the ant raft, if you have waves or currents," Hagemann observed, underscoring the robustness of the assembled structures in dynamic environments.
An Ingenious Latching Mechanism
The secure yet releasable connection between the robotic units is facilitated by an elegantly designed latching mechanism concealed within each hull. At the core of this mechanism is a single servo motor that drives an origami-inspired auxetic structure. Auxetic materials possess the unique property of contracting uniformly in all directions when stretched, or expanding when compressed. In the FloatForm system, this geometry facilitates the movement of permanent magnets. When the servo motor retracts the structure, the magnets are pulled inward, releasing the connection. Conversely, when the structure expands, the magnets are pushed outward, engaging with neighboring robots.
The magnets are strategically arranged with alternating polarities, ensuring that the robots reliably interlock to form precise square lattices. A significant engineering achievement is the energy efficiency of this latching system. A 3D-printed gearbox allows the latch to remain in either its engaged or disengaged state with the central motor switched off, thus minimizing power consumption.
"It uses energy to latch and de-latch, but in between those states, it doesn’t use any energy," explained Hagemann. This is a critical consideration for infrastructure that might need to maintain a configuration for extended periods. Gonzalez-Garcia added, "Because the robots are so small, you can only have a battery so big. If they use less energy on latching, they can use more on computation, or on actually moving."
Developing this robust and efficient system involved overcoming several engineering hurdles. The four miniature thrusters, arranged in an ‘X’ configuration, provide each robot with omnidirectional motion, including the ability to turn in place. However, their high power relative to the robots’ low inertia initially led to twitchy behavior and aggressive spins at low speeds. To address this, the team incorporated stabilizing fins to increase hydrodynamic drag and meticulously tuned the control algorithms to ensure robustness, compensating for the inherent variations in robots at this miniature scale. The magnetic latches themselves presented a challenge, as their strong attraction sometimes required robots to actively twist to disengage.
From Controlled Environments to Open Waters
The FloatForm system has demonstrated impressive reliability in controlled laboratory settings. Across ten trials involving four robots, the system completed its missions autonomously 90 percent of the time. With eight robots, this success rate was 70 percent. Crucially, when unexpected issues arose, the decentralized architecture proved resilient. A robot that temporarily lost its bearings could autonomously rejoin the structure without disrupting the entire swarm. Similarly, robots encountering formation deadlocks learned to self-correct and retry their actions, showcasing the system’s ability to recover from minor failures.
Transitioning from the controlled environment of an indoor test tank to the complexities of a real canal or harbor presents a new set of challenges. "There’s always a relationship between the size of a boat and the magnitude of the disturbance it can handle," observed Gonzalez-Garcia. "These boats are very small, so in very disturbed water, they cannot work."
Scaling up the technology will necessitate strengthening the latches, potentially incorporating mechanical interlocking systems similar to those used in the full-size Roboat project. Furthermore, the current ultrasonic indoor positioning system will need to be replaced with more robust navigation solutions such as GPS or vision-based sensing for open-water applications. A significant advantage of the FloatForm’s coordination algorithm is its sensor-agnostic design, meaning the core logic can be retained even with the integration of different sensing technologies.
The researchers envision a wide array of applications extending beyond urban waterways. Potential uses include the deployment of temporary platforms for offshore inspection and maintenance operations, the creation of adaptive sensor networks for studying migratory marine species, and the development of reconfigurable docking stations for emergency response in remote or difficult-to-access areas. The system also holds promise for offshore and remote operations, such as temporary construction platforms and vital environmental monitoring during scientific expeditions.
The geographical potential is vast. "Venice, the Netherlands, Belgium, the fjords and lakes of Norway, really any city with a river can take advantage of this," stated Gonzalez-Garcia. "The project uses spaces where water is already important, but it also raises the question: Where else can water be used for something more?"
Steven Ceron, an Assistant Professor at the University of Michigan who was not involved in the research, commented on the significance of the work. "This is an exciting step forward in realizing distributed collective behaviors on water," Ceron said. "Assembly, self-reconfiguration, and collective motion are difficult enough in dry environments, but achieving these behaviors in a predominantly distributed fashion on water represents a serious additional challenge, and this team has credibly overcome it. By shifting the computational burden onto the robots themselves, they have built a more resilient system that in the near future could enable robot collectives like this to be deployed in open-water environments for search operations, environmental monitoring, and reconfigurable marine infrastructure."
The research paper was authored by Gonzalez-Garcia, Hagemann, and Wang, with senior authors Carlo Ratti and Daniela Rus. Gonzalez-Garcia also holds an affiliation with the MECO Research Team at KU Leuven. The project received funding from the Amsterdam Institute for Advanced Metropolitan Solutions, with additional support from the University of Wisconsin at Madison. The research team also expressed gratitude to MIT Sea Grant and Professor Michael Triantafyllou for providing access to the test tank facilities.