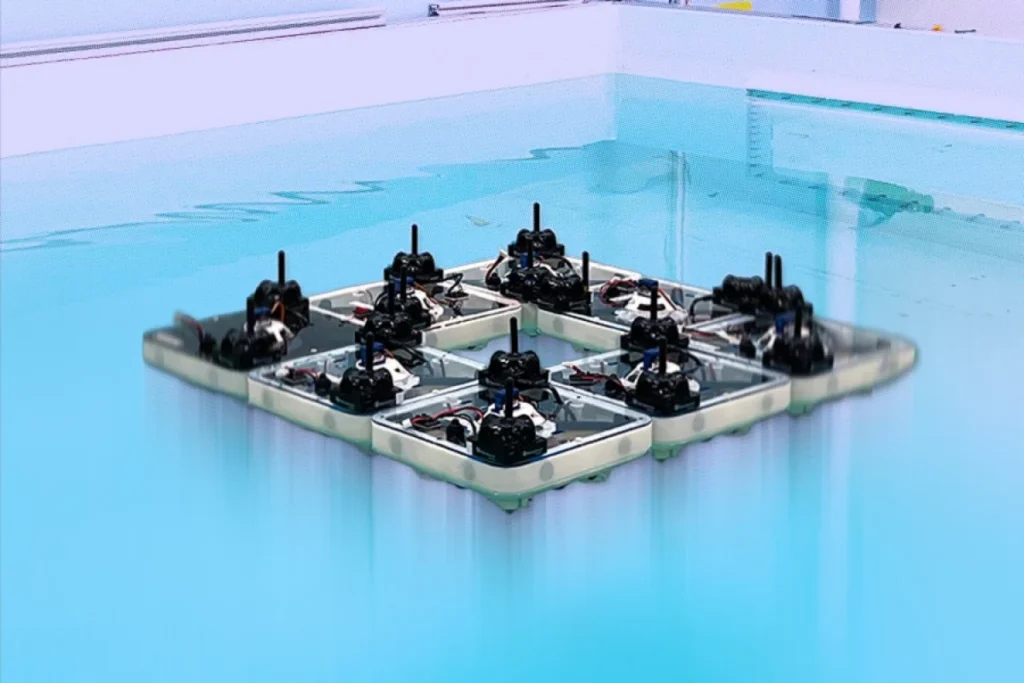
A groundbreaking system developed by a team of researchers at the Massachusetts Institute of Technology (MIT) promises to transform how we interact with urban waterways, envisioning a future where waterfronts are not static boundaries but dynamic, programmable extensions of the city. This innovative technology, named FloatForm, utilizes a swarm of small, square robotic boats capable of self-assembling into larger structures, reconfiguring into new forms, and even acting as a unified vessel, all with minimal human intervention.
The implications of FloatForm are far-reaching, suggesting a paradigm shift in urban infrastructure, emergency response, public space utilization, and even mobile commerce. The system, detailed in a recent publication in the prestigious journal Nature Communications, draws inspiration from the natural world and builds upon years of research into autonomous marine robotics at MIT.
The Genesis of a Dynamic Waterfront: From Roboat to FloatForm
The FloatForm project is a direct evolution of MIT’s earlier "Roboat" initiative, a collaborative effort with the Amsterdam Institute for Advanced Metropolitan Solutions. Roboat explored the potential of full-scale autonomous vessels to navigate and perform tasks in the canals of Amsterdam, a city historically shaped by its waterways. The Roboat project investigated how these canals, once vital arteries for commerce, could be repurposed for modern urban needs such as waste collection, goods transport, and even ferrying passengers, thereby alleviating pressure on congested road networks.
"We explored whether the canals could be used for waste collection, or for transport, to offload some of the stress on the roads back onto the water," explains Niklas Hagemann, an MIT graduate student in architecture and a researcher involved in both projects. "Urban areas are getting denser, so could you expand public space onto water that’s currently underutilized?"
While Roboat focused on individual, larger autonomous boats, FloatForm tackles a more complex challenge: orchestrating the coordinated behavior of a multitude of smaller robotic units. The team scaled down the vision to a "tabletop" size to address the intricate problem of how dozens, and potentially thousands, of independent floating robots could autonomously organize themselves into functional structures.
Inspired by Nature: The Ant Raft Analogy
The key to FloatForm’s decentralized assembly lies in a surprising biological model: the fire ant. When faced with floods, fire ants exhibit a remarkable survival strategy by linking their bodies together to form resilient, living rafts. Crucially, this collective action occurs without a central leader directing each ant. Instead, each ant adheres to simple local rules, leading to the emergent formation of a robust and adaptable structure.
"Each ant is an independent agent," states Alejandro Gonzalez-Garcia, a former researcher with MIT’s Computer Science and Artificial Intelligence Laboratory (CSAIL) and the Senseable City Lab, and a key contributor to the FloatForm project. "We wanted each robot to have its own capabilities, the same way ant colonies form a raft."
This biological inspiration contrasts sharply with many existing self-assembling robot systems, which often rely on a central computer to dictate every movement. Such centralized control systems are inherently vulnerable to single points of failure and struggle to scale efficiently. As the number of robots increases, the computational complexity of planning grows exponentially, often leading to sequential assembly where most robots remain idle, awaiting their turn.
FloatForm, by contrast, shifts the balance of control. A lightweight central planner is employed sparingly, primarily to assign each robot a final target position to ensure geometric precision in the assembled structure. The critical tasks of navigation, collision avoidance, and adaptation to disturbances are handled by the robots themselves. They achieve this through local communication, exchanging positional information with their immediate neighbors, allowing the entire swarm to move and reconfigure simultaneously.
"What we’re trying to do is to have minimal central intervention, and have them all move together at the same time," Gonzalez-Garcia elaborates. This parallel processing approach significantly reduces the computational burden. The complexity of planning for FloatForm is dependent only on a robot’s immediate neighbors, not the total number of robots in the swarm, making it inherently scalable.
Engineering the Swarm: Design and Functionality
Each FloatForm robot is a compact, self-contained unit, approximately 21 centimeters square, about the size of a dinner plate. Equipped with individual thrusters for omnidirectional movement, sophisticated sensors for navigation and environmental awareness, and a unique magnetic latching mechanism, these robots are designed for modularity and resilience.
The magnetic latching system is a marvel of engineering, drawing inspiration from origami principles. Hidden within each hull, a central servo motor drives an auxetic structure – a geometry that contracts uniformly in all directions. This mechanism pulls in or pushes out permanent magnets positioned on all four sides of the robot. This allows for precise connections, forming clean square lattices when robots engage and releasing them when needed. The alternating polarity of the magnets ensures reliable and secure coupling.
A significant design advantage of this latching system is its energy efficiency. Once latched or unlatched, the mechanism maintains its state without continuous power consumption, thanks to a 3D-printed gearbox. "It uses energy to latch and de-latch, but in between those states, it doesn’t use any energy," notes Hagemann. This is a critical consideration for small robots with limited battery capacity, allowing them to allocate more power to computation and movement.
The omnidirectional motion is achieved through four miniature thrusters arranged in an "X" configuration. While providing exceptional maneuverability, these thrusters initially presented a challenge due to their powerful thrust relative to the robots’ small inertia, leading to unstable spins in early prototypes. The research team addressed this by incorporating stabilizing fins to increase hydrodynamic drag and by meticulously tuning the control algorithms to ensure robust performance across robots that, at this scale, inherently exhibit minor variations.
Demonstrating Capability: From Lab Tank to Future Applications
Experiments conducted at MIT have showcased FloatForm’s impressive capabilities. In controlled tests, a fleet of eight robots successfully executed complex maneuvers. They repeatedly transitioned from random positions to a predefined target shape, latched to form a rigid structure, detached on command, reassembled into a new configuration, and then navigated across the test pool as a single, unified vessel. Each complete cycle, from assembly to collective transport, took approximately four to eight minutes.
In the collective transport mode, a central planner defines the overall trajectory, and each robot calculates its individual contribution to propel the assembled structure. "Every robot becomes an actuator," explains Gonzalez-Garcia. Simulations have further validated the system’s scalability, demonstrating smooth performance with swarms of up to 64 robots.
The resilience of the FloatForm system was also evident during the trials. In 10 experimental runs, the system achieved its missions without human intervention 90% of the time with four robots and 70% with eight. When minor issues arose, such as a robot temporarily losing its bearings, the distributed architecture allowed it to autonomously rejoin the structure without disrupting the entire swarm. Robots that encountered formation deadlocks were able to resolve them and retry their maneuvers.
Broader Implications: Redefining Urban Mobility and Public Space
The potential applications of FloatForm extend far beyond experimental demonstrations. The researchers envision a future where waterfronts become programmable spaces, offering unprecedented adaptability and utility.
Adaptive Infrastructure: FloatForm could provide on-demand infrastructure. Imagine temporary bridges appearing to alleviate traffic congestion during emergencies or special events. Floating platforms could serve as temporary markets, concert stages, or even emergency shelters.
Enhanced Urban Livability: By enabling the utilization of water surfaces, FloatForm can help expand public spaces in increasingly dense urban environments. This could lead to more recreational areas, vibrant waterfront districts, and a greater connection between city dwellers and their waterways.
Emergency Response: In disaster scenarios, where traditional infrastructure may be compromised, FloatForm robots could quickly assemble into functional bridges, medical platforms, or evacuation routes, providing crucial support in hard-to-reach areas.
Environmental Monitoring and Research: The system could deploy adaptive sensor networks for studying marine ecosystems, tracking migratory species, or conducting environmental monitoring in challenging offshore locations.
Offshore and Remote Operations: FloatForm could facilitate temporary construction platforms for offshore maintenance, scientific expeditions, or other remote operations where traditional construction methods are impractical.
Challenges and the Road Ahead
While the current research is promising, scaling FloatForm for real-world deployment presents several challenges. Moving from a controlled indoor tank to dynamic open-water environments like canals or harbors will require significant advancements.
"There’s always a relationship between the size of a boat and the magnitude of the disturbance it can handle," notes Gonzalez-Garcia. "These boats are very small, so in very disturbed water, they cannot work." Future iterations will likely involve reinforcing the latching mechanisms, potentially incorporating mechanical interlocking systems similar to those used in the larger Roboat vessels.
Furthermore, transitioning from the lab’s ultrasonic indoor positioning to robust outdoor navigation will necessitate the adoption of GPS or advanced vision-based sensing technologies. Fortunately, the FloatForm coordination algorithm has been designed to be sensor-agnostic, meaning the core logic can remain intact while different sensing modalities are integrated.
The researchers are optimistic about the future. "Whether you are working with eight boats or 80, the entire fleet coordinates and moves simultaneously," says Wei Wang, lead author of the Nature Communications paper and a former MIT research scientist. "Because the overall assembly time doesn’t significantly increase in principle, the system remains highly scalable."
Expert Perspectives and Future Vision
The work has garnered attention from the broader robotics and urban planning communities. Steven Ceron, an Assistant Professor at the University of Michigan who was not involved in the research, commented on the significance of the achievement. "This is an exciting step forward in realizing distributed collective behaviors on water," Ceron stated. "Assembly, self-reconfiguration, and collective motion are difficult enough in dry environments, but achieving these behaviors in a predominantly distributed fashion on water represents a serious additional challenge, and this team has credibly overcome it." Ceron highlighted the potential for such robot collectives in search operations, environmental monitoring, and reconfigurable marine infrastructure.
The vision extends beyond the immediate applications. The researchers envision a world where cities can leverage their waterways in entirely new ways. "Venice, the Netherlands, Belgium, the fjords and lakes of Norway, really any city with a river can take advantage of this," says Gonzalez-Garcia. "The project uses spaces where water is already important, but it also raises the question: Where else can water be used for something more?"
The development of FloatForm was supported by grants from the Amsterdam Institute for Advanced Metropolitan Solutions and the University of Wisconsin at Madison, with additional contributions from MIT Sea Grant and Professor Michael Triantafyllou for providing the test tank facilities. The research team, including authors Gonzalez-Garcia, Hagemann, Wang, and senior authors Carlo Ratti and Daniela Rus, continues to push the boundaries of what is possible with autonomous robotics, paving the way for a future where our cities and their waterfronts are more adaptable, responsive, and integrated than ever before.