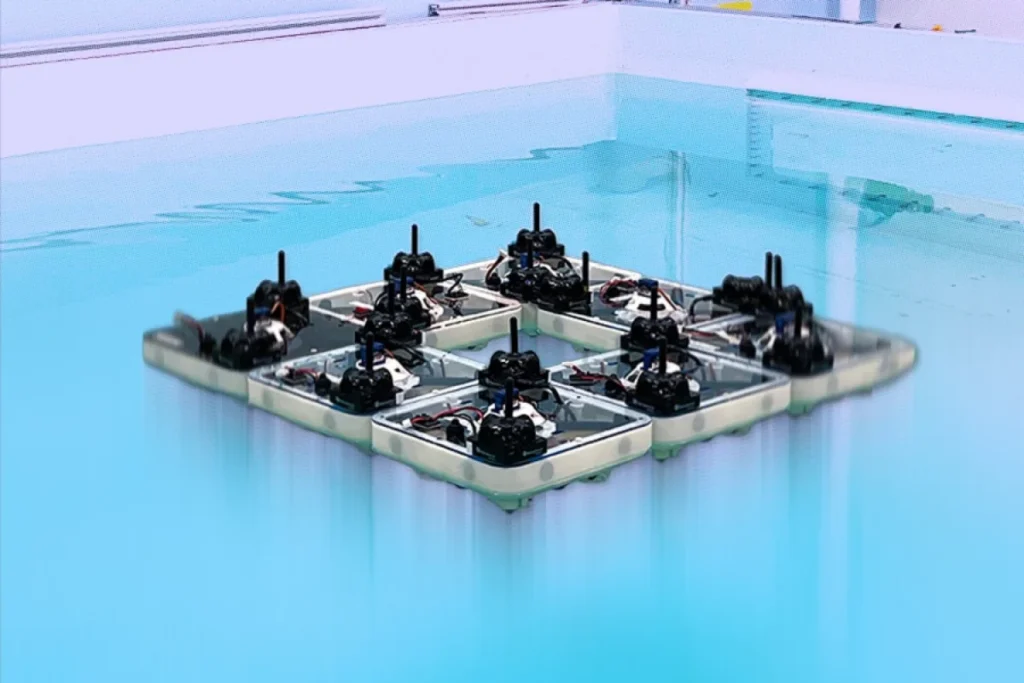
A team of researchers at the Massachusetts Institute of Technology (MIT) has unveiled an innovative robotic system, dubbed FloatForm, that reimagines the potential of urban waterfronts. Moving beyond the traditional perception of the waterfront as a static boundary, FloatForm envisions it as a dynamic, adaptable construction site, capable of self-assembling and reconfiguring into a variety of floating structures on demand. This groundbreaking technology, detailed in a recent publication in Nature Communications, utilizes a swarm of small, square robotic boats that can autonomously connect, form larger structures, break apart, and then reform into something entirely new, all with minimal human oversight.
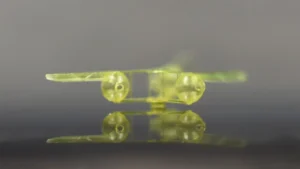
Each individual FloatForm robot is approximately the size of a dinner plate, measuring 21 centimeters square. These self-contained vessels are equipped with their own thrusters for propulsion, sensors for environmental awareness, and sophisticated magnetic latches for inter-robot connectivity. The collective capabilities of these robots hint at a future where aquatic infrastructure can be fluid and responsive to urban needs. Potential applications range from the rapid deployment of temporary platforms in emergency situations to the creation of ephemeral floating markets along canals or the construction of stages for public events that can dissolve once the festivities conclude.
A Programmable Extension of the City: The Vision Behind FloatForm
Daniela Rus, the Panasonic Professor of Electrical Engineering and Computer Science at MIT and director of the Computer Science and Artificial Intelligence Laboratory (CSAIL), articulated the far-reaching implications of the FloatForm project. "Our FloatForm project envisions a future where the waterfront becomes a programmable extension of the city," Rus stated. "Autonomous boats can self-organize into bridges, platforms, and other useful structures on demand. This kind of distributed robotics opens new possibilities for mobility, emergency response, public space, and infrastructure on water."
Wei Wang, the lead author of the Nature Communications paper and a former MIT research scientist now heading the Marine Robotics Lab at the University of Wisconsin at Madison, elaborated on this transformative potential. "With FloatForm, we are essentially turning static water surfaces into dynamic, programmable spaces," Wang explained. "Imagine an urban environment where public space isn’t fixed, but can autonomously expand, contract, or reconfigure on demand."
The concept of modularity is central to FloatForm’s design. Alejandro Gonzalez-Garcia, a former researcher with MIT CSAIL and the Senseable City Lab, emphasized this aspect. "We see it as forming infrastructure on the water, using a modular system to create one larger system," Gonzalez-Garcia said. "If there’s an emergency, you could form a new bridge to alleviate traffic in the city. Or you could create floating markets and floating stages. If you want a more livable city, you want to use the water, too."
This research builds upon the foundational work of the Roboat project, a collaboration between MIT and the Amsterdam Institute for Advanced Metropolitan Solutions. Roboat explored the use of full-size autonomous vessels in Amsterdam’s canals, originally conceived as a means to alleviate road congestion by shifting goods transport back to the waterways. Niklas Hagemann, an MIT graduate student in architecture and CSAIL affiliate who has been involved with the project since its early stages, highlighted the evolution of this thinking. "We explored whether the canals could be used for waste collection, or for transport, to offload some of the stress on the roads back onto the water," Hagemann noted. "Urban areas are getting denser, so could you expand public space onto water that’s currently underutilized?" FloatForm scales this ambitious vision down to a more manageable, yet technically complex, challenge: orchestrating the collective behavior of dozens, and potentially thousands, of smaller floating robots.
Inspiration from Nature: The Ant Raft Analogy
The breakthrough in enabling such a complex swarm behavior came from an unexpected source: biology. The researchers drew inspiration from the remarkable ability of fire ants to survive floods by forming living rafts, where individual ants link together without a central leader dictating their actions. Each ant, acting as an independent agent, follows simple local rules, resulting in the emergence of a resilient and cohesive structure.
"Each ant is an independent agent," Gonzalez-Garcia reiterated. "We wanted each robot to have its own capabilities, the same way ant colonies form a raft." This biological parallel directly informed the design philosophy of FloatForm, moving away from traditional centralized control systems that are common in robotic swarms.
Decentralized Control: A More Scalable and Resilient Approach
Most existing self-assembling robotic systems, whether on land or water, rely on a central computer to meticulously plan and direct every robot’s movement. This approach, however, is inherently vulnerable to single points of failure; if the central controller malfunctions, the entire swarm can be incapacitated. Furthermore, the computational burden of such systems grows exponentially with the number of robots, making large-scale deployments impractical. Such systems also often necessitate sequential assembly, where many robots remain idle while waiting for their turn to connect.
FloatForm flips this paradigm by adopting a largely decentralized control architecture. A lightweight central planner is employed only sparingly, primarily to assign each robot its ultimate desired position within the final structure, ensuring a level of geometric precision that purely distributed methods can struggle to achieve. The crucial difference lies in the fact that navigation, collision avoidance, and adaptation to environmental disturbances are handled autonomously by the robots themselves. They coordinate by exchanging positional information with their immediate neighbors, allowing the entire swarm to move and assemble simultaneously.
This parallel processing capability is a key differentiator. The complexity of planning for FloatForm depends only on the interactions between a robot and its local neighbors, rather than the total size of the swarm. "What we’re trying to do is to have minimal central intervention, and have them all move together at the same time," explained Gonzalez-Garcia.
Experimental Validation and Collective Transport
In controlled experiments conducted at MIT, a fleet of eight FloatForm robots demonstrated remarkable agility. The robots were observed to repeatedly move from random starting positions to a designated target shape, latch together to form a rigid structure, then break apart on command. They would then reassemble into a new configuration and proceed to traverse a test pool as a unified vessel. Each of these cycles, from initial assembly to collective movement, typically took between four to eight minutes.
A particularly innovative feature is the "collective transport" mode. In this scenario, a central planner defines a trajectory for the entire assembled structure, and each individual robot calculates its specific contribution to executing that trajectory. "Every robot becomes an actuator," Gonzalez-Garcia elaborated. This distributed approach to locomotion ensures that the entire structure moves cohesively and efficiently. Simulations have further validated the system’s scalability, showing that the framework can smoothly accommodate swarms of up to 64 robots.
The inherent scalability of the FloatForm system was highlighted by Wei Wang. "The beauty of this largely decentralized approach is that the computation doesn’t get bogged down as the swarm grows," Wang stated. "Whether you are working with eight boats or 80, the entire fleet coordinates and moves simultaneously. Because the overall assembly time doesn’t significantly increase in principle, the system remains highly scalable."
Beyond computational efficiency, the physical robustness of the assembled structures is also enhanced. Niklas Hagemann pointed out the advantages of collective buoyancy and stability: "Our boats become more stable by joining together, like the ant raft, if you have waves or currents." This enhanced stability is critical for reliable operation in dynamic aquatic environments.
An Ingenious Latching Mechanism: The Origami Handshake
The seamless connection and disconnection of the FloatForm robots are facilitated by an ingenious latching mechanism, cleverly concealed within each hull. This mechanism is driven by a single servo motor at the center of each robot, which actuates an origami-inspired auxetic structure. Auxetic materials are known for their ability to contract uniformly in all directions when stretched or compressed. In this application, the auxetic structure allows the robot’s internal magnets to either retract, releasing a neighboring robot, or extend, securely grasping it.
The magnets are strategically arranged with alternating polarities, ensuring that the robots reliably align and click into precise square lattice formations. A significant design advantage of this mechanism is its energy efficiency. Once a latch is engaged or disengaged, a 3D-printed gearbox holds it in place without requiring continuous power. "It uses energy to latch and de-latch, but in between those states, it doesn’t use any energy," explained Hagemann. This is a critical consideration for small robots with limited battery capacity, as it allows them to conserve energy for computation and movement rather than constant latch maintenance. "Because the robots are so small, you can only have a battery so big," added Gonzalez-Garcia. "If they use less energy on latching, they can use more on computation, or on actually moving."
The path to this elegant solution involved overcoming significant engineering hurdles. Each robot is equipped with four miniature thrusters arranged in an ‘X’ configuration, providing omnidirectional movement and the ability to pivot in place. However, these thrusters generate substantial force relative to the robots’ small inertia, which initially led to prototypes that were overly twitchy and prone to rapid, uncontrolled spins at low speeds. To mitigate this, the team incorporated stabilizing fins to increase hydrodynamic drag and meticulously tuned the control algorithms. This tuning was essential to ensure robust performance across a fleet of robots, as even at this scale, no two robots are perfectly identical. The magnetic latches themselves presented another challenge; they were so powerful that releasing them sometimes required the robots to physically twist themselves free, necessitating further refinement of the latching and unlatching dynamics.
From Controlled Environments to Open Waters: The Path Forward
Rigorous testing has demonstrated the system’s reliability. Across 10 trials, the FloatForm system achieved its objectives without human intervention 90% of the time with four robots and 70% of the time with eight robots. Importantly, the decentralized architecture proved resilient to individual robot failures. If a robot temporarily lost its bearings or became momentarily disengaged, it could autonomously rejoin the structure without halting the entire swarm. Robots that encountered formation deadlocks also learned to resolve these issues by shaking themselves free and retrying the connection process.
The transition from controlled indoor test tanks to real-world canal or harbor environments presents new challenges. "There’s always a relationship between the size of a boat and the magnitude of the disturbance it can handle," acknowledged Gonzalez-Garcia. "These boats are very small, so in very disturbed water, they cannot work." Scaling up the system will require strengthening the latches, potentially incorporating mechanical interlocking features similar to those used in the full-size Roboat project. Furthermore, the indoor ultrasonic positioning systems will need to be replaced with more robust outdoor navigation solutions like GPS or vision-based sensing. Fortunately, the core coordination algorithm was designed to be sensor-agnostic, meaning the underlying logic can be retained even when the sensory input changes.
The potential applications for FloatForm extend far beyond urban waterways. The researchers envision its use in forming temporary platforms for offshore inspection and maintenance operations, deploying adaptive sensor networks for ecological studies of migratory species, and establishing reconfigurable docking stations for emergency response in remote or inaccessible areas. Offshore and remote operations, including temporary construction platforms, environmental monitoring, and scientific expeditions, also represent significant potential use cases.
The geographical reach of this technology is vast. "Venice, the Netherlands, Belgium, the fjords and lakes of Norway, really any city with a river can take advantage of this," Gonzalez-Garcia suggested. "The project uses spaces where water is already important, but it also raises the question: Where else can water be used for something more?"
Steven Ceron, an Assistant Professor at the University of Michigan who was not involved in the research, commented on the significance of the work. "This is an exciting step forward in realizing distributed collective behaviors on water," Ceron stated. "Assembly, self-reconfiguration, and collective motion are difficult enough in dry environments, but achieving these behaviors in a predominantly distributed fashion on water represents a serious additional challenge, and this team has credibly overcome it. By shifting the computational burden onto the robots themselves, they have built a more resilient system that in the near future could enable robot collectives like this to be deployed in open-water environments for search operations, environmental monitoring, and reconfigurable marine infrastructure."
The research paper detailing the FloatForm system was authored by Alejandro Gonzalez-Garcia, Niklas Hagemann, and Wei Wang, with senior authorship from Carlo Ratti and Daniela Rus. Gonzalez-Garcia also holds an affiliation with the MECO Research Team at KU Leuven. The project received funding from the Amsterdam Institute for Advanced Metropolitan Solutions, with additional support from the University of Wisconsin at Madison. The team expressed gratitude to MIT Sea Grant and Professor Michael Triantafyllou for providing the necessary test tank facilities for their experiments.